-
4.2.5
-
Positioning control
The following describes the I/O variables of MC_MoveAbsolute.
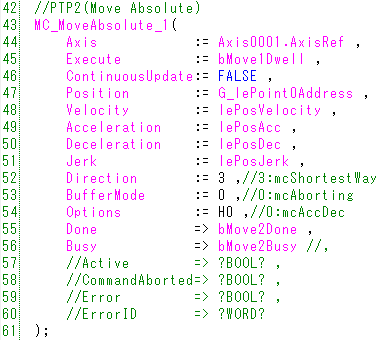
<MC_MoveAbsolute specification (extract)>
| I/O variable name | Variable name | Data type | Description | |
| Input | Execution command | Execute | BOOL | Executes the positioning control when TRUE is set. |
| Continuous update | ContinuousUpdate | BOOL | The movement distance, velocity, acceleration, and deceleration can be continuously changed while TRUE is set. | |
| Target position | Position | LREAL | Sets the target position of the absolute position according to the axis unit. | |
| Velocity | Velocity | LREAL | Sets the velocity according to the axis unit. | |
| Acceleration | Acceleration | LREAL | Sets the acceleration according to the axis unit. | |
| Deceleration | Deceleration | LREAL | Sets the deceleration according to the axis unit. | |
| Jerk | Jerk | LREAL | Sets the jerk according to the axis unit. | |
| Direction selection | Direction | MC_DIRECTION | Selects the moving direction. →4.2.5-5 page | |
| Buffer mode | BufferMode | MC_BUFFER_MODE | Selects the buffer mode. →4.2.5-4 page | |
| Option | Options | DWORD(HEX) | Sets the function option. →4.2.5-6 page | |
| Output | Execution completion | Done | BOOL | Turns TRUE after the positioning control is completed. |
| Executing | Busy | BOOL | Turns TRUE while the FB is being executed. | |
| Controlling | Active | BOOL | Turns TRUE when the FB is controlling the axis. | |
| Abortion of execution | CommandAborted | BOOL | Turns TRUE when the execution is aborted. | |
| Error | Error | BOOL | Turns TRUE when an error occurs in the FB. | |
| Error code | ErrorID | WORD (UINT) |
Returns the error code occurred in the FB. | |
-
 Motion Module User's Manual (Application)
- 6.1 Single Axis Positioning Control
- Absolute Positioning Control
- MELSEC iQ-R Programming Manual (Motion Control Function Blocks)
- 3.2 Operation FBs
MC_MoveAbsolute